Looking for the latest information on 03 3 Replace Euler With Quaternion? We've gathered comprehensive data, records, and insights about 03 3 Replace Euler With Quaternion.
Main Features
Explore the primary sources for 03 3 Replace Euler With Quaternion.
Latest News
Stay updated on 03 3 Replace Euler With Quaternion's latest milestones.
Euler angles to Quaternions
Computing Euler Angles: Tracking Attitude Using Quaternions
3D Rotations and Quaternion Exponentials: Special Case
Handling Independent Camera Elevation in Three.js with Quaternion Rotations
2.2 Rotation Without Tears: Euler Angles, Matrices & Quaternions | Math & Physics Survival Kit
PID with Euler Angles and Quaternion
euler quaternion
Euler and quaternion coordinates for orientation
PD with Euler Angles and Quaternion
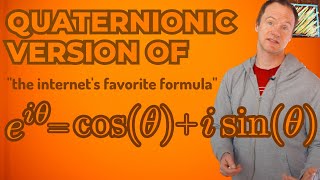
a quaternion version of Euler's formula
lez 03 :Attitude kinematics: Euler theorem and quaternions
Expert Insights
Data is compiled from public records and verified media reports.
Last Updated: September 28, 2026
Final Thoughts
For 2026, 03 3 Replace Euler With Quaternion remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Go experience the explorable videos: eater.net/ Part of my MSc Computer games and Entertainment Maths assignment. In this video we continue our discussion on how to track the attitude of a body in space using In this video, we'll understand 3D rotations from the point of view of vector analysis and Learn how to implement independent camera elevation in Demystify 3D rotations in robotics without the mathematical headaches. We compare Proportional, Integral and Derivative controller using We explain the set of matrices that represent orientation: Special orthogonal matrices. We explain how the Proportional and derivative controller using WHAT IS THIS? INK? INK?! SINCE WHEN ARE YOU INTO...UGH...INK? OH MY GOODNESS HOW COUL- :AHHHHHHHHH: ... You should not ai propri un nuovo re di bepi kroos produt between one recto rendon ad are no ken dire presenti through matrix