Overview on Autonomous Navigation In Unknown Environments With Sparse Bayesian Kernel Based Occupancy Mapping
Looking for the latest information on Autonomous Navigation In Unknown Environments With Sparse Bayesian Kernel Based Occupancy Mapping? We've researched comprehensive data, records, and insights about Autonomous Navigation In Unknown Environments With Sparse Bayesian Kernel Based Occupancy Mapping.
Core Information
Explore the main sources for Autonomous Navigation In Unknown Environments With Sparse Bayesian Kernel Based Occupancy Mapping.
History
Stay updated on Autonomous Navigation In Unknown Environments With Sparse Bayesian Kernel Based Occupancy Mapping's newest achievements.
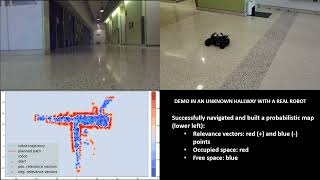
Autonomous Navigation in Unknown Environments using Sparse Kernel-based Occupancy Mapping
FOVEATED 2.5D MAPPING || LiDAR + Deep Learning for Autonomous Navigation
High-speed autonomous navigation in the unknown environment
Indoor autonomous navigation in unknown environments
Provably Safe Autonomous Navigation in Unknown Environments
Learning-aided 3D Occupancy Mapping with Bayesian Generalized Kernel Inference
PATH PLANNING: AMR navigation and mapping
Learning-based 3D Occupancy Prediction for Navigation in Occluded Environments
Autonomous Navigation
Autonomous Navigation of Mobile Robot in Unknown Environments
Expert Insights
Data is compiled from public records and verified media reports.
Last Updated: September 29, 2026
Final Thoughts
For 2026, Autonomous Navigation In Unknown Environments With Sparse Bayesian Kernel Based Occupancy Mapping remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
This paper focuses on real-time In this video, we present our Foveated 2.5D FoveaMap turns raw 3D LiDAR into a foveated 2.5D semantic Accepted to IEEE Transactions on Robotics 2019. Kevin Doherty, Tixiao Shan, Jinkun Wang, and Brendan Englot. Video for the ICRA 2021 submission. Learning-
Autonomous Navigation In Unknown Environments With Sparse Bayesian Kernel Based Occupancy Mapping.pdf
What is the most accurate information about Autonomous Navigation In Unknown Environments With Sparse Bayesian Kernel Based Occupancy Mapping?
Our platform aggregates the most comprehensive and up-to-date insights, ensuring you get relevant details about Autonomous Navigation In Unknown Environments With Sparse Bayesian Kernel Based Occupancy Mapping.
Why is Autonomous Navigation In Unknown Environments With Sparse Bayesian Kernel Based Occupancy Mapping trending right now?
Interest in Autonomous Navigation In Unknown Environments With Sparse Bayesian Kernel Based Occupancy Mapping has surged recently as more people seek reliable resources, related media, and detailed analysis.
Where can I find related media and updates for Autonomous Navigation In Unknown Environments With Sparse Bayesian Kernel Based Occupancy Mapping?
You can explore extensive galleries, video summaries, and related content directly on this page.
How often is the content about Autonomous Navigation In Unknown Environments With Sparse Bayesian Kernel Based Occupancy Mapping updated?
We regularly update our database with the latest information, media, and analysis related to Autonomous Navigation In Unknown Environments With Sparse Bayesian Kernel Based Occupancy Mapping.