Looking for the latest information on Cs225 Trajectory Generation? We've researched comprehensive data, records, and insights about Cs225 Trajectory Generation.
Core Information
Explore the primary sources for Cs225 Trajectory Generation.
Latest News
Stay updated on Cs225 Trajectory Generation's newest achievements.
6.8210 Spring 2024 Lecture 11: Trajectory Optimization II
[Tutorial] Optimization, Optimal Control, Trajectory Optimization, and Splines
Real-Time Generation of Time-Optimal Quadrotor Trajectories with Semi-Supervised Seq2Seq Learning
Polynomial Trajectories with Large Number of Waypoints to Follow Continuous-Path Trajectories (UAV)
Real-Time Safe Trajectory Generation for Quadrotor Flight in Cluttered Environments
Rocket guidance and flight trajectory control
Stanford CS25: Transformers United V6 I From Language Models to Native Multimodal Intelligence
5 4 Time, Motion, and Trajectories continued University of Pennsylvania Coursera
UbiComp/ISWC 2023 AeroTraj: Trajectory Planning for Fast, and Accurate 3D Reconstruction
Trajectory Forcing: Structure-First Generation with Controllable Semantic Trajectories (ECCV 2026)
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: October 1, 2026
Final Thoughts
For 2026, Cs225 Trajectory Generation remains one of the most talked-about information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
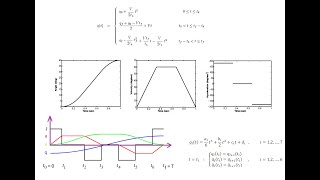
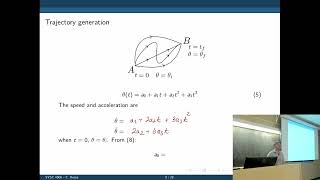
Different methods of generating parametric trajectories (joint variables as a function of time) for In this lecture we're going to study More projects at robotics-trail.github.io. In this paper, we propose a data-driven method for real-time time-optimal We address the problem of real-time For more information about Stanford's graduate programs, visit: online.stanford.edu/graduate-education May 21, 2026 This ... Project Page: mervekocabas.github.io/Trajec...