Looking for the latest information on Dynamic Obstacle Avoidance Test? We've compiled comprehensive data, records, and insights about Dynamic Obstacle Avoidance Test.
Important Facts
Explore the main sources for Dynamic Obstacle Avoidance Test.
History
Stay updated on Dynamic Obstacle Avoidance Test's latest milestones.
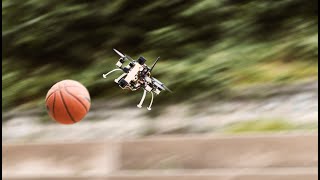
Rapid, Dynamic Obstacle Avoidance with an Event-based Camera
Scenario 2 unknown dynamic obstacle avoidance
Obstacle Avoidance Algorithm
Dynamic Obstacle Avoidance for Quadrotors with Event Cameras (Science Robotics 2020)
DYNAMIC OBSTACLE AVOIDANCE USING LIDAR | BOTICX LABS
Dynamic Obstacle Avoidance for Mobile Robots Using Vision-Based Deep Reinforcement Learning - Test 1
UGV Path Planning and Dynamic Obstacles Avoidance Test Video
ROS Rviz Mobile Robot Dynamic Obstacle Avoidance Test
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: October 1, 2026
Future Outlook
For 2026, Dynamic Obstacle Avoidance Test remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
In this tutorial I did several experiments to train a robot to avoid This project is Group 667's Robotics Bachelor's Thesis from Aalborg University. The project was focused on creating a robot which ... In this work, we study the effects that perception latency has on the maximum speed a robot can reach to safely navigate through ... FOWMR's aware-control hierarchical framework for unknown This short video details the methods and results from a model predictive control based Today's autonomous drones have reaction times of tens of milliseconds, which is not enough for navigating fast in complex ... Creativity is intelligence having fun .. Lab is always fun playing with technology, team having fun while This video demonstrates how the robot, UGV (Unmanned Ground Vehicle) can detect and avoid any With advanced tracking capabilities and 360°