Looking for the latest information on Dynamic Obstacle Avoidance? We've researched comprehensive data, records, and insights about Dynamic Obstacle Avoidance.
Key Details
Explore the main sources for Dynamic Obstacle Avoidance.
Recent Updates
Stay updated on Dynamic Obstacle Avoidance's latest milestones.
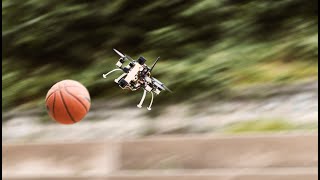
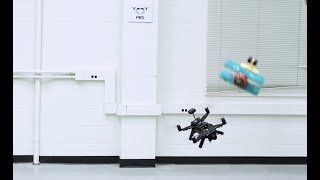
Dynamic Obstacle Avoidance for Quadrotors with Event Cameras (Science Robotics 2020)
myAGV | Check Out How to Implement Dynamic Obstacle Avoidance in ROS2 for Autonomous Guided Vehicles
EVDodgeNet: Deep Dynamic Obstacle Dodging with Event Cameras [ICRA 2020]
Online Trajectory Generation for 6 DOF Manipulators with Dynamic Obstacle Avoidance
Reactive Neural Path Planning with Dynamic Obstacle Avoidance in a Condensed Configuration Space
Dynamic Obstacle Avoidance with Model Predictive Trajectory Generator(MPTG) - ERP42
ORCA - MPCC with static and dynamic obstacle avoidance
Enforcing Constraints for Dynamic Obstacle Avoidance by Compliant Robots
Model based Dynamic Obstacle Avoidance on Inclined Surface
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: September 27, 2026
Future Outlook
For 2026, Dynamic Obstacle Avoidance remains one of the most talked-about information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
In this tutorial I did several experiments to train a robot to avoid In this work, we study the effects that perception latency has on the maximum speed a robot can reach to safely navigate through ... With advanced tracking capabilities and 360° Thrilled to announce that the Origin One now utilizes proprietary Today's autonomous drones have reaction times of tens of milliseconds, which is not enough for navigating fast in complex ... Discover how our mobile robot myAGV leverages ROS2 to achieve intelligent navigation in In this video, we demonstrate the experimental results of a novel online trajectory generation method designed for 6 DOF ... A biologically inspired approach for path planning with This short video details the methods and results from a model predictive control based This video demonstrates how the robot, UGV (Unmanned Ground Vehicle) can detect and avoid any 2023 IEEE International Conference on Robotics and Automation (ICRA), London, United Kingdom Authors: Leonidas Koutras, ... Demonstration of a Gaussian process (GP) potential field method introduced in the ME5001 (master's) project “Model-based ...