Looking for the latest information on Efficient Gait Learning In Simulation? We've researched comprehensive data, records, and insights about Efficient Gait Learning In Simulation.
Main Features
Explore the main sources for Efficient Gait Learning In Simulation.
History
Stay updated on Efficient Gait Learning In Simulation's newest achievements.
Lizard Gait Simulation -- walk in gait 1
Learning Speed-Adaptive Walking Agent Using Imitation Learning with Physics-Informed Simulation
Simulation of human gait with continuous PD controller
High-Speed Locomotion Control Using Reinforcement Learning with a Pacing Gait Style
Lizard Gait Simulation -- turn in gait 1
Learning Robot Gait Stability
Evolved Muscle Model and ANN Gaits
Fast and Efficient Locomotion via Learned Gait Transitions
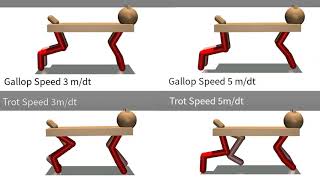
Deep Reinforcement Learning with Gait Mode Specification for Quadrupedal Trot-Gallop Energetic Study
Biomimetic Synthetic Gait - First successful simulation
Gait Simulator
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: September 29, 2026
Conclusion
For 2026, Efficient Gait Learning In Simulation remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
The objective of this experiments is to develop feasible Energy Minimization based locomotion policies can generate the most energy- This is an example of a simVITRO system performing This video demonstrate how our lizard turn direction in This video shows our work on using neural networks as sensory feedback function for central pattern generators. The CPG ... Evolved gaits using the muscle model that emerged from the different replicate runs. Multiple unique Paper: arxiv.org/pdf/2104.04644.pdf We focus on the problem of developing energy Note that the data on the computer was from a previous test run. It would have been better to show data from this specific test run ...