Looking for the latest information on Graph Based Slam? We've gathered comprehensive data, records, and insights about Graph Based Slam.
Core Information
Explore the key sources for Graph Based Slam.
History
Stay updated on Graph Based Slam's latest milestones.
Robust Least Squares for Graph-Based SLAM (Cyrill Stachniss)
MIT Robotics - Frank Dellaert - Factor Graphs for Perception and Action
Factor Graphs + TagSLAM For Efficient Map and Pose Optimization
Graph-Based SLAM with Landmarks (Cyrill Stachniss)
Wolfram Burgard, Giorgio Grisetti, and Cyrill Stachniss: Graph-based SLAM in 20 Minutes
Factor Graphs and Robust Perception | Michael Kaess | Tartan SLAM Series
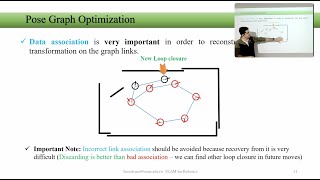
Graph Based SLAM and Loop Closure
TUM AI Lecture Series - Pushing Factor Graphs beyond SLAM (Frank Dellaert)
EKF-SLAM (Cyrill Stachniss)
Frank Dellaert | Factor Graphs for Perception and Action | Tartan SLAM Series
Introduction to SLAM (Cyrill Stachniss)
Full Guide
Data is compiled from public records and verified media reports.
Last Updated: September 27, 2026
Conclusion
For 2026, Graph Based Slam remains one of the most talked-about information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
This video provides some intuition around Pose Simultaneous Localization and Mapping ( MIT - December 3, 2021 Frank Dellaert "Factor How do robots really know where they are — not just guess? In this video, we dive deep into the world of Factor This is a short video lecture by Wolfram, Giorgio, and Cyrill explaining A presentation by Michael Kaess as part of the Tartan Filtering methods the Extended Kalman Filter fail due to quadratic complexity in state size. Abstract: Many estimation, planning and optimal control problems in robotics have an optimization problem at their core. In most of ... Presentation by Frank Dellaert titled, "Factor Introduction to the Simultaneous Localization and Mapping Problem (