Looking for the latest information on Graph Search Path Planning? We've compiled comprehensive data, records, and insights about Graph Search Path Planning.
Core Information
Explore the main sources for Graph Search Path Planning.
Latest News
Stay updated on Graph Search Path Planning's newest achievements.
Path Planning with A* and RRT | Autonomous Navigation, Part 4
A* (A Star) Search and Heuristics Intuition in 2 minutes
Visibility Graph Algorithm: Optimal Path Planning in Polygonal Environments
Path Planning with GNNs (Graph Neural Networks)
A* Graph Search (Motion Planning)
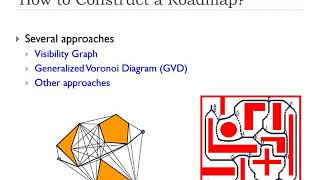
Roadmap Based Path Planning: Visibility Graph and Generalised Voronoi Diagrams as roadmaps
COMP 361- Graph-based Path Planning
Lecture 36: Path planning, Graph Searches, and the A* Algorithm
Advanced 1. Incremental Path Planning
mod06lec32 - Graph Search Methods
Graph-based Path Planning for Autonomous Robotic Exploration in Subterranean Environments
Full Guide
Data is compiled from public records and verified media reports.
Last Updated: September 30, 2026
Conclusion
For 2026, Graph Search Path Planning remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
... about motion planning for quite a while so I'm labeling this as part one and the first part of this is TurtleBot 2D Optimization-Based For the source code : github.com/HalukErdogan/ros-astar-demo. See the other videos in this series: youtube.com/playlist?list=PLn8PRpmsu08rLRGrnF-S6TyGrmcA2X7kg This video ... Created by Kamyar Ghiam and Anish Krishnan: Kamyar Ghiam: kamyarghiam Anish Krishnan: ... This video demonstrates the Visibility In this video, I introduce two important concepts in robot Course Title: Introduction to Application of Artificial Intelligence to Robotics Whether you're a student, researcher, or robotics ... MIT 16.412J Cognitive Robotics, Spring 2016 View the complete course: ocw.mit.edu/16-412JS16 Instructor: MIT students ... This work presents a new strategy for autonomous