Looking for the latest information on Graph Slam Demonstration? We've researched comprehensive data, records, and insights about Graph Slam Demonstration.
Core Information
Explore the main sources for Graph Slam Demonstration.
Recent Updates
Stay updated on Graph Slam Demonstration's newest achievements.
Understanding SLAM Using Pose Graph Optimization | Autonomous Navigation, Part 3
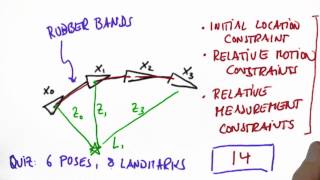
Graph-Based SLAM with Landmarks (Cyrill Stachniss)
graph-slam demo: Loading a raw graph file vs. its Dijkstra tree global estimation:
SLAM - 5 Minutes with Cyrill
Radar-Inertial ICP-based Pose Graph SLAM
ProSLAM: Graph SLAM from a Programmer's Perspective
Graph SLAM with occupancy grid - ISAM FLIRT in ROS
Dynamic Pose Graph SLAM Demonstration
Graph SLAM Solution - Artificial Intelligence for Robotics
Graph SLAM with Clearpath Husky and Velodyne VLP-16s
SLAM - Graph-based SLAM - Freiburg79, 2011
Expert Insights
Data is compiled from public records and verified media reports.
Last Updated: September 29, 2026
Final Thoughts
For 2026, Graph Slam Demonstration remains one of the most talked-about information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
A plethora of localization solutions for different sensor modalities exists, yet robust sensing in degraded perception conditions ... The robot is estimating its pose and surrounding map simultaneously. The map is represented as a occupancy grid. Under the ... Used as the base-line in: Henrik Kretzschmar and Cyrill Stachniss Information-Theoretic Compression of Pose