Introduction on Init Pose Function For Robot Web Tool
Looking for the latest information on Init Pose Function For Robot Web Tool? We've gathered comprehensive data, records, and insights about Init Pose Function For Robot Web Tool.
Important Facts
Explore the primary sources for Init Pose Function For Robot Web Tool.
History
Stay updated on Init Pose Function For Robot Web Tool's newest achievements.
Programatically Setting of Robot's Initial Pose
[ROS Q&A] 121 - How to Write Robot Poses to a File
Sending Goal Pose Programetically
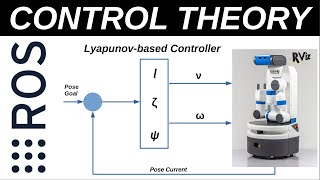
Control Theory | Lyapunov | Moving to Pose | ROS | RViz
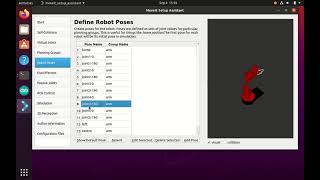
ROS MoveIt poses
TAX-Pose: Task-Specific Cross-Pose Estimation for Robot Manipulation
Pose Estimation using Whycon markers [ROS]
Active Rendezvous for Multi-Robot Pose GraphOptimization using Sensing over Wi-Fi
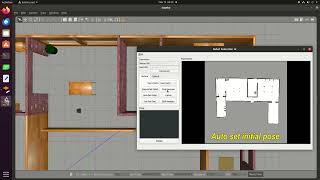
ROS Robot Localization: Auto set initial pose
P3-DX robot pose control in Gazebo simulator
How to set the initial robot pose in ROS2 Navigation | ROS2 Developers Open Class #146
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: October 1, 2026
Final Thoughts
For 2026, Init Pose Function For Robot Web Tool remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Convert 16 bit binary signal into numerical value, then assign into x,y,z coordinate through the use of Traditionally, after launching rviz in ROS, the initial In this video we are going to see how to write This videos shows an automated Goal (using python code) In this video, I demonstrate the implementation of a Lyapunov-based Controller applied to mobile I found that it took quite a bit of testing and adjusting the motion planning output and conversion for use by the Arduino to control ... Paper link : arxiv.org/abs/1907.05538. This project help localization the The control algorithm: Graceful Controller ( www-personal.umich.edu/~jongjinp/) For a correct Navigation pipeline, it is very important that your