Looking for the latest information on Motion Planning Using Rrt Connect? We've compiled comprehensive data, records, and insights about Motion Planning Using Rrt Connect.
Main Features
Explore the primary sources for Motion Planning Using Rrt Connect.
Developments
Stay updated on Motion Planning Using Rrt Connect's newest achievements.
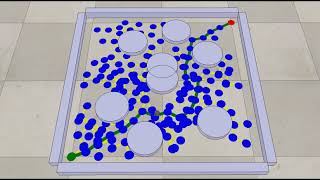
2D Motion planning using RRT-connect
3d Motion Planning using RRT-connect
Path Planning using RRT-Connect
RRT connect.avi
Path Planning using RRT-Connect
RRT-Connect Motion Planning with Pinocchio Demonstration
Introduction to Motion Planning Algorithms | Motion Planning with the RRT Algorithm, Part 1
RRT Path Planning with Kinodynamic Trajectory Generation
Human Aware Robot Motion Planning using RRT Algorithm in Industry 4.0
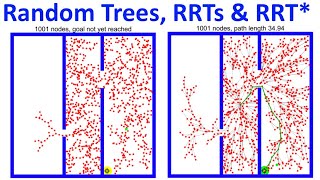
RRT, RRT* & Random Trees
Motion Planning - RRT Sampling method
Full Guide
Data is compiled from public records and verified media reports.
Last Updated: October 1, 2026
Conclusion
For 2026, Motion Planning Using Rrt Connect remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Rapidly Exploring Trees searching bidirectionally for a Rapidly-exploring Random Trees ( HW 2 Given Start and Goal Configurations. This is a demonstration for coursework related to the Advanced Robotics course at the University of Edinburgh. Experimentation was performed on a python-based Quadrotor simulator. Path Lecture 24 of Intro to Robotics @ University of Houston.