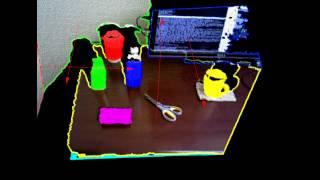
Looking for the latest information on Object Segmented Using Pcl? We've compiled comprehensive data, records, and insights about Object Segmented Using Pcl.
Core Information
Explore the key sources for Object Segmented Using Pcl.
Developments
Stay updated on Object Segmented Using Pcl's newest achievements.
ROS2 segmentation using pcl crop box and indices
ROS/PCL 3D-Segmentation Using a Depth Sensor
Labelme: AI Oriented Bounding Boxes for Cars with SAM3
E42 Biao Zhang Point Cloud Instance Segmentation using Probabilistic Embeddings
ROS2 PCL Point Cloud Clustering and Cylindrical Segmentation
3D Unsupervised Point Cloud Segmentation in Python : Efficient Guide (1M Points/Sec)
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: September 29, 2026
Summary
For 2026, Object Segmented Using Pcl remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
The objective of this project is to lay the foundations for A structured learning path for becoming a robotics developer. : bit.ly/4v1OplB Voxel grid filtering in linkedin.com/in/antoniomaurogaliano This video shows a ROS2 node which is able to get data from a 3D laser ... CODE: github.com/hoangcuongbk80/ A new Labelme feature that turns AI-generated masks into oriented (rotated) bounding boxes in a single . In this demo, an ... Hidden Course → learngeodata.eu/course/spatial-ai-operating-system Get 3D Assets ...