Looking for the latest information on Occupancy Grid? We've researched comprehensive data, records, and insights about Occupancy Grid.
Important Facts
Explore the key sources for Occupancy Grid.
Developments
Stay updated on Occupancy Grid's latest milestones.
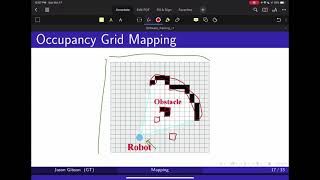
Occupancy Grids | Path Planning
Occupancy grid map algorithm running real-time on FPGA
Lecture 12-Occupancy Grid Mapping
Navigation with Occupancy Grids Only
Probabilistic Occupancy Grid Mapping Using Monocular Vision
Mapping on occupancy grid with Iterative Closest Point algorithm
Occupancy grid using Lidar
Information Based Exploration with Panoramas and Angle Occupancy Grids
Occupancy grid map -- from given data
Robot Mapping and Exploration: Occupancy Grid Mapping with Breshenham Ray Casting (EECS 467 A2)
OccupancyGrid.m4v
Expert Insights
Data is compiled from public records and verified media reports.
Last Updated: September 29, 2026
Future Outlook
For 2026, Occupancy Grid remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
This video is part of the RoboJackets Software Training Program for Fall 2021. robojackets.org/training/software-training/ MOBILE ROBOTICS: METHODS & ALGORITHMS - WINTER 2022 University of Michigan - NA 568/EECS 568/ROB 530 For slides, ... Demo of a novel method to generate a probabilistic ENLACE interns Yoatzin and Ziyun implemented mapping on A live experiment with two robots demonstrating the exploration method presented in the DARS 2016 paper with the same title. Read more on the Breshenham's line algorithm here: en.wikipedia.org/wiki/Bresenham%27s_line_algorithm. The easiest way for a robot to map its environment is using an