Visual-Inertial ORB-SLAM in EuRoC MAV Dataset - V1_02_medium
ORB-SLAM: Mapping KAIST campus with Monocular Camera
ORB SLAM Monocular
ORB-SLAM vs motion capture system Augmented Reality comparison
ORB SLAM-3 Simulation test
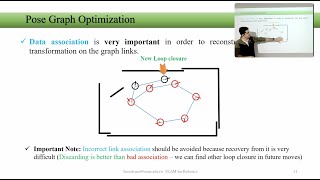
CH13 SLAM for Robotics Course - ORB-SLAM algorithm details, Pose Graph Optimization, (SIFT, ORB)
Full Guide
Data is compiled from public records and verified media reports.
Last Updated: September 27, 2026
Summary
For 2026, Orb Slam Accuracy remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Repo: github.com/luigifreda/pyslam. Since its first publication in 2015, This is a demonstration of ORB_SLAM3 performing visual Get FREE Robotics & AI Resources (Guide, Textbooks, Courses, Resume Template, Code & Discounts) – Sign up via the pop-up ... Raúl Mur-Artal and Juan D. Tardós. "Visual-Inertial Monocular For more information, please visit our website. vdclab.kaist.ac.kr/bbs/board.php?bo_table=sub2_2&sca=Localization. A cropped video from ( youtube.com/watch?v=sr9H3ZsZCzc). Done for education purpose. On the left, the localization of the camera is computed using Done as a part of the ESE 650 project. Simultaneous Localization and Mapping (