Optimal Communication Planning for Distributed Loop Closure Detection
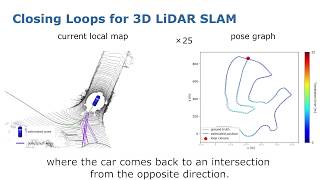
RSS'20: OverlapNet - Loop Closing for LiDAR-based SLAM by Chen et al.
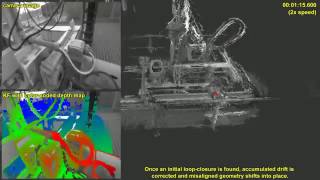
VI-SLAM multiple loops without loop closure
Outdoor closed loop experiment at Campus Birlinghoven
A Heuristic Loop Closing Technique for Large-Scale 6D SLAM
Loop-Closure Detection in Urban Scenes for Autonomous Robot Navigation - 3DV 2017
Assigning Visual Words to Places for Loop Closure Detection
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: September 29, 2026
Future Outlook
For 2026, Outdoor Loop Closing remains one of the most talked-about information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Using ORB SLAM2 from link github.com/raulmur/ORB_SLAM2 with some modifications. Talk Resource-Efficiently to Me: Optimal Communication Planning for Distributed X. Chen, T. Läbe, A. Milioto, T. Röhling, O. Vysotska, A. Haag, J. Behley, and C. Stachniss, “OverlapNet: Andreas Nüchter, Kai Lingemann, Joachim Hertzberg, and Hartmut Surmann. Heuristic-Based Laser Scan Matching for Jochen Sprickerhof, Andreas Nüchter, Kai Lingemann, and Joachim Hertzberg. A Heuristic By means of a probability function, the mechanism is capable of identifying a