Looking for the latest information on Path Tracking With Pid Controller? We've gathered comprehensive data, records, and insights about Path Tracking With Pid Controller.
Key Details
Explore the primary sources for Path Tracking With Pid Controller.
Recent Updates
Stay updated on Path Tracking With Pid Controller's latest milestones.
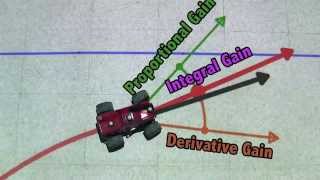
1. Driverless RC Car: Simple PID - Path Tracking
System Modeling: Path Tracking for Differential Steering Drive Autonomous Robots
TurtleBot Path Tracking using PID Controller
Controlling Self Driving Cars
Trajectory Tracking for Autonomous Vehicles Using PID and MPC Controllers
[PythonRobotics] Path tracking simulation with LQR steering control and PID speed control.
PID Controllers For Game Devs
Evaluation of a PID controller for waypoint-based path tracking of an Ackermann steering robot
Comparison between PID and MPC Drift Controller
Autonomous Path Tracking with PID Steering and Speed Control
[PythonRobotics] Path tracking with rear wheel feedback steering control and PID speed control
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: September 28, 2026
Conclusion
For 2026, Path Tracking With Pid Controller remains one of the most talked-about information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Want to learn industrial automation? Go here: realpars.com ▷ Want to train your team in industrial automation? Go here: ... This is based on Artificial Intelligence for Robotics Course at Udacity. The project uses Arduino UNO and a speed sensor. [IEEE CSS Video Clip Contest 2015 Submission] This is a video introduction to controlling self-driving cars, specifically using ... Code is here: github.com/AtsushiSakai/PythonRobotics/blob/master/PathTracking/lqr_steer_control/lqr_steer_control.py ... Learn to architect real systems, structure your code, and build scalable game projects ... More info: redmond redmond.dynamics Autonomous driving DNANO RC Car (1:43) Comparison between Target Speed Constant = 50 Source code at: github.com/xmfcx/carnd-t2-p4-