Looking for the latest information on Structured Domain Randomization? We've compiled comprehensive data, records, and insights about Structured Domain Randomization.
Important Facts
Explore the main sources for Structured Domain Randomization.
History
Stay updated on Structured Domain Randomization's latest milestones.
Domain Randomization with Fetch robot with Gazebo and ROS
NPDR -- Combining Likelihood-Free Inference, Normalizing Flows, and Domain Randomization
ROS Developers LIVE-Class #40: Domain randomization with ROS, Gazebo and Fetch | part 1
Domain Randomization
Training with Domain Randomization
Lecture 22 Sim2Real and Domain Randomization -- CS287-FA19 Advanced Robotics at UC Berkeley
Object Detection Using Sim2Real Domain Randomization for Robotic Applications - ICRA23 preview video
Flow-based Domain Randomization for Learning and Sequencing Robotic Skills
Domain Randomization for Neural Network Classification - Journal of Big Data
Crashing to Learn, Learning to Survive: Planning in dynamic environments via domain randomization
Simulation for Real World Robotics
Expert Insights
Data is compiled from public records and verified media reports.
Last Updated: September 29, 2026
Conclusion
For 2026, Structured Domain Randomization remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
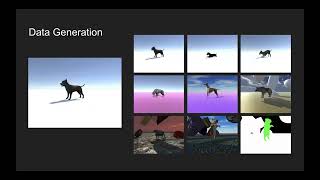
To help make deep learning more accessible, researchers from NVIDIA have introduced a On our approach to randomizing objects, texture and other scene components within the realistic values. Structured Domain Randomization In this series, we explore using reinforcement learning algorithms (RL) to have a robot learn to balance on its own. We will deploy ... These are the final results we have obtained on reproducing the paper results How can we learn a control policy in simulation such that it transfers to the real robot if all we have is a non-differentiable ... In this class, we are going to see how to reproduce the results of the famous paper " Course Instructor: Pieter Abbeel Guest Lecturer: Josh Tobin Course Website: ... Authors: Dániel Horváth, Gábor Erdős, Zoltán Istenes, Tomáš Horváth, and Sándor Földi ... We address the issue of mobile robot navigation in dynamic environments. Paper: ... ... fields including simulation, semantic/scene understanding, reinforcement learning,