Looking for the latest information on The Orbital Stabilization Problem? We've researched comprehensive data, records, and insights about The Orbital Stabilization Problem.
Core Information
Explore the key sources for The Orbital Stabilization Problem.
History
Stay updated on The Orbital Stabilization Problem's latest milestones.
On Excessive Transverse Coordinates for Orbital Stabilization of Periodic Motions (IFAC WC 2020)
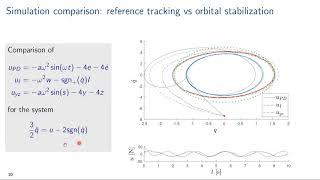
On Orbital Stabilization as an alternative to Reference Tracking Control (AMC2020)
Orbital Stabilization of Nonlinear Systems via the Immersion and Invariance Technique
Chapter 6 9 Orbital stability
Orbital stabilization of an underactuated bipedal gait via nonlinear H-infinity-control
Orbital Stabilization of Single Body Walker
Orbital Stabilization on Rought Terrain
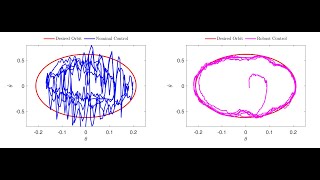
Robust Output-Feedback Orbital Stabilization of Underactuated Mechanical Systems
A. Pousse “On the stability of co-orbital motion in the three-body problem”
Orbit Stabilizer Theorem Example
Newton’s three-body problem explained - Fabio Pacucci
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: September 30, 2026
Future Outlook
For 2026, The Orbital Stabilization Problem remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
First of three videos where go through the presentation from my PhD defense. Thesis available at: ... Visual Group Theory, Lecture 5.2: MY DIFFERENTIAL EQUATIONS PLAYLIST: ... Talk given at the IFAC World Congress, July, 2020 Title: On Excessive Transverse Coordinates for Talk given at the IEEE International Workshop on Advanced Motion Control (AMC2020). Authors: Christian Fredrik Sætre and ... Romeo Ortega, Bowen Yi, José Guadalupe Romero, Alessandro Astolfi - The Immersion and Invariance (I&I) technique developed ... for nearly circular orbits it is possible to calculate whether The primary concern of the work is robust control of hybrid mechanical systems under unilateral constraints with underactuation ... This video is a brief overview of the controller design for a single body walking robot. The controlled system is actuated with ... The experiments were carried out at the Robust Control Laboratory Instituto Politécnico Nacional Center of Research and ... Download a free audiobook version of "The Three-Body