Looking for the latest information on Behavior Trees C Ros 2 Groot? We've researched comprehensive data, records, and insights about Behavior Trees C Ros 2 Groot.
Important Facts
Explore the key sources for Behavior Trees C Ros 2 Groot.
Developments
Stay updated on Behavior Trees C Ros 2 Groot's latest milestones.
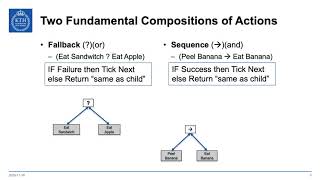
Behavior Trees for ROS2 | ROS2 Developers Open Class #162
Behavior Trees (C++) + ROS 2 + Groot
Behavior Trees in Robotics (Part 2 - C++ Implementation)
5 minute Behavior Tree tutorial
Groot: prepare development environment
Bump And Go (Behavior Trees + ROS2 + Turtlebot3)
Behavior Tree BT.CPP + Groot with Navigation2
20200104 BehaviorTree_CPP library on ROS2
Inside a Robot’s Mind: How Behavior Trees Make Perfect Decisions | ROS2 Explained
Navigation2 Groot Monitor
Behaviour Trees
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: October 2, 2026
Future Outlook
For 2026, Behavior Trees C Ros 2 Groot remains one of the most talked-about information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
In this project, AMR is using the See a TurtleBot3 mobile robot in the Gazebo simulator navigating an environment using Aplicación de Ejemplo simulando un comportamiento propio de un robot de limpieza, usando Árboles de Comportamiento, ... This is a 5 minute introduction to Text instructions: marufabbasi.github.io/ Aplicación robótica Bump And Go usando Ever wondered how robots make split-second decisions in chaotic environments—choosing between charging, delivering, ... Example of a gopher robot at Yujin running a delivery through a