Looking for the latest information on Real Time Appearance Based Mapping? We've compiled comprehensive data, records, and insights about Real Time Appearance Based Mapping.
Key Details
Explore the primary sources for Real Time Appearance Based Mapping.
Recent Updates
Stay updated on Real Time Appearance Based Mapping's latest milestones.
Real Time Appearance Based Mapping in point clouds
How to Build a 3D Map with RTAB-VSLAM on Raspberry Pi 5
RTAB Mapping - indoor mapping with zed2
I experimented an autonomous moving by using RTAB-Map
How to Make an Autonomous Mapping Robot Using SLAM
Real-Time Visual Localisation and Mapping with a Single Camera
Real-time Photorealistic Mapping for Situational Awareness in Robot Teleoperation
Real-time reconstruction of a long corridor with FAST Mapping
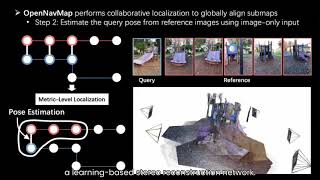
OpenNavMap: Multi-Session Appearance-Based Topometric Mapping for Scalable Visual Navigation
Full Guide
Data is compiled from public records and verified media reports.
Last Updated: September 29, 2026
Future Outlook
For 2026, Real Time Appearance Based Mapping remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
In this video, I demonstrate how to use SLAM (Simultaneous Localization and Watch the Hiwonder MentorPi M1 Raspberry Pi 5 robot car demonstrate RTAB-VSLAM ( I experimented Autonomous Moving by using RTAB-Map( This video explains the basics of SLAM (Simultaneous Localization and In my work over the past five years I have generalised the Simultaneous Localisation and Scene reconstruction is performed exclusively using the RGB-D camera ; all other cameras are used only to illustrate the setup ... This video shows the reconstruction of a long corridor in a university building. It was done by FAST Title: OpenNavMap: Multi-Session