eXactoPOSE: Real-time Visual Servoing with Force Control
Shape Control of Variable Length Continuum Robots using Clothoid-based Visual Servoing
Eye-to-hand image-based visual servoing
Safe and Robust Image-Based Visual Servoing for Industrial Robotic Manipulation
Lab 4: Visual Servoing
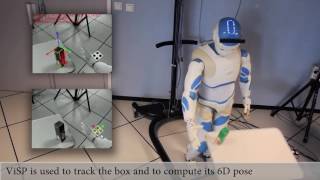
Visual Servoing in an Optimization Framework for the Whole-body Control of Humanoid Robots
Position Based Visual Servoing
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: October 1, 2026
Final Thoughts
For 2026, Visual Servoing System remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
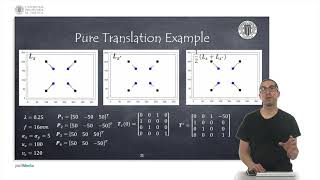
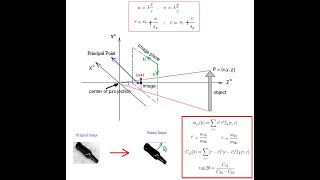
This video explains how to implement robot image-based Basics of computer-vision for image-based control of robotic arms are explained in this video, including the pinhole camera model ... Bringing robotics and vision together! This video demonstrates an innovative control technique where a camera, mounted on a ... Ever wondered how robots 'see' and precisely manipulate objects? This video dives into the fundamental principles behind A demonstration of a control method known as To bring about a new era in industrial robotics by overcoming challenges such as high costs, restrictive environment, and safety ... eXactoPOSE is a robot control technology that allows the robot to fuse sensor data from multiple sources of position and force ... For more information about this project please visit our lab website: wp.wpi.edu/merlab/encoderless-robots/ In this paper, ... This video is the internal view of the camera used to RSS Spring 2020 Team 5: Detecting and parking in front of a colored cone.