Introduction of Exploration Multi Robot Exploration
Looking for the latest information on Exploration Multi Robot Exploration? We've researched comprehensive data, records, and insights about Exploration Multi Robot Exploration.
Core Information
Explore the main sources for Exploration Multi Robot Exploration.
Developments
Stay updated on Exploration Multi Robot Exploration's latest milestones.
Master Thesis: Multi-Robot Collaborative Autonomous Exploration With Text
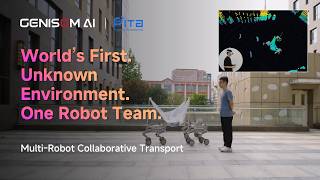
Global Debut | Multi-Legged Cooperative Transport System
Sampling-based multi-robot exploration
Density-Aware Efficient and Collaborative Multi-Robot Exploration
Time-Sensitive Exploration of Three-Dimensional Environments with Multi-Robot Teams
[IEEE TVT] Multi-Robot Cooperative Exploration via Deep Reinforcement Learning
Contact-Guided Exploration for Non-Prehensile Locomanipulation with Multi-Critic RL
Indoor Mapping and Localization Across a Whole Warehouse
Distributed Multi Robot Exploration
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: October 1, 2026
Conclusion
For 2026, Exploration Multi Robot Exploration remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Paper Accepted to IROS 2023. Authors: Ehsan Latif and Prof. Ramviyas Parasuraman School of Computing, University of Georgia ... Heriot-Watt University School of Mathematical and Computer Sciences Master in This video showcases our thesis work during the spring of 2023. Four Turtlebot3 Zhi Yan, Nicolas Jouandeau, and Arab Ali Cherif. Sampling-based This method enables a team of heterogeneous Reference: Micah Corah. Sensor Planning for Large Numbers of This work is published in IEEE Transactions on Vehicular Technology. For more details, please check: ... This video shows experiments of the project done in simulation and on one real ROSbot. The simulation shows the performances ... Teaching a Quadruped to Push, Pull, and Move Objects with Reinforcement Learning * How can a Lakeside Labs and NES institute of the Alpen-Adria-Universität are working on autonomous