Looking for the latest information on Distributed Mapping With Two Robots? We've researched comprehensive data, records, and insights about Distributed Mapping With Two Robots.
Core Information
Explore the primary sources for Distributed Mapping With Two Robots.
Latest News
Stay updated on Distributed Mapping With Two Robots's newest achievements.
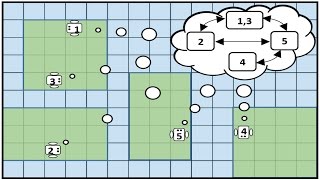
Distributed Consistent Multi-Robot Semantic Localization and Mapping
Distributed Multi Robot Exploration
Distributed Multi-Robot Formation Splitting and Merging in Dynamic Environments
Map API - Distributed Robotic Mapping
ISTSC-1: Distributed Consistent Multi-Robot Semantic Localization and Mapping
Distributed Multi-robot Exploration and Mapping
ROAM | Distributed Multi-robot Exploration
DiSCo-SLAM: Distributed Multi-Robot LiDAR SLAM With Two-Stage Global-Local Graph Optimization
IMRDFS Exploration and Mapping Strategy using Two Mobile Robots on a Graph
A Distributed Reconfiguration Planning Algorithm for Modular Robots
How to Make an Autonomous Mapping Robot Using SLAM
Expert Insights
Data is compiled from public records and verified media reports.
Last Updated: September 30, 2026
Conclusion
For 2026, Distributed Mapping With Two Robots remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Video supplement to our ICRA submission. For questions, please contact awc11 Abstract: This paper presents a ... We deployed ROAM on a team of manually-controlled ground Lakeside Labs and NES institute of the Alpen-Adria-Universität are working on autonomous multi- Video to our ICRA paper: asl.ethz.ch/people/slynen/personal/paper/2015_icra_map_api.pdf. The 1st Israeli Smart Transportation Students Conference (ISTSC-1) was hosted by Bar-Ilan University on December, 3 2020. Efficient exploration of unknown environments is a fundamental problem in multi- A novel framework is proposed for Experimental Evaluation of the Improved Multi This video explains the basics of SLAM (Simultaneous Localization and