Background to Learning To Propagate Interaction Effects For Modeling Deformable Linear Objects Dynamics
Looking for the latest information on Learning To Propagate Interaction Effects For Modeling Deformable Linear Objects Dynamics? We've researched comprehensive data, records, and insights about Learning To Propagate Interaction Effects For Modeling Deformable Linear Objects Dynamics.
Core Information
Explore the main sources for Learning To Propagate Interaction Effects For Modeling Deformable Linear Objects Dynamics.
Developments
Stay updated on Learning To Propagate Interaction Effects For Modeling Deformable Linear Objects Dynamics's latest milestones.
Shape Control of Deformable Linear Objects
Deformable Linear Object
An Interactive Simulator for Deformable Linear Objects Manipulation Planning
ICRA2021 - Deformable Linear Object Prediction Using Locally Linear Latent Dynamics
Shape Control of Deformable Linear Objects with Offline and Online Learning of Local Linear ...
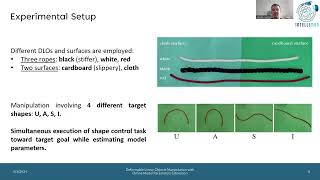
Deformable Linear Objects Manipulation with Online Model Parameters Estimation
RMDO 2024: Deformable Linear Objects Manipulation with Online Model Parameters Estimation
Global Model Learning for Large Deformation Control of Elastic Deformable Linear Objects
MultiAC6: A Framework to Control Large 3D Deformation of Soft Linear Objects
Deformable Objects Manipulation Using Model Adaptation Techniques
Learning Latent Graph Dynamics for Deformable Object Manipulation
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: September 30, 2026
Future Outlook
For 2026, Learning To Propagate Interaction Effects For Modeling Deformable Linear Objects Dynamics remains one of the most talked-about information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Presentation by Yuxuan at ICRA 2021. This video overviews our approach to This video accompanies our ICRA 2021 paper " Spotlight talk at 2nd Workshop on Representing and Manipulating Title: Presenting ReForm, a Robot Video for ICRA 2022 Paper "Shape Control of This is a working prototype built using constraint potentials for deriving forces (popularized by Terzopoulos and Teschner). Nahum Alvarez, Kimitoshi Yamazaki: “An Interactive Simulator for Authors: Wenbo Zhang, Karl Schmeckpeper, Pratik Chaudhari, and Kostas Daniilidis GRASP Lab, University of Pennsylvania, ... IEEE Robotics and Automation Letters (RA-L) 2024 Abstract: Manipulating Spotlight talk at 4th Workshop on Representing and Manipulating Paper accepted by IEEE Transactions on Robotics (T-RO). Project website: mingrui-yu.github.io/shape_control_DLO_2. The paper "Multi Actor-Critic DDPG for Robot Action Space Decomposition: A Framework to Control Large 3D Deformation of Soft ...
Learning To Propagate Interaction Effects For Modeling Deformable Linear Objects Dynamics.pdf
What is the most accurate information about Learning To Propagate Interaction Effects For Modeling Deformable Linear Objects Dynamics?
Our platform aggregates the most comprehensive and up-to-date insights, ensuring you get relevant details about Learning To Propagate Interaction Effects For Modeling Deformable Linear Objects Dynamics.
Why is Learning To Propagate Interaction Effects For Modeling Deformable Linear Objects Dynamics trending right now?
Interest in Learning To Propagate Interaction Effects For Modeling Deformable Linear Objects Dynamics has surged recently as more people seek reliable resources, related media, and detailed analysis.
Where can I find related media and updates for Learning To Propagate Interaction Effects For Modeling Deformable Linear Objects Dynamics?
You can explore extensive galleries, video summaries, and related content directly on this page.
How often is the content about Learning To Propagate Interaction Effects For Modeling Deformable Linear Objects Dynamics updated?
We regularly update our database with the latest information, media, and analysis related to Learning To Propagate Interaction Effects For Modeling Deformable Linear Objects Dynamics.